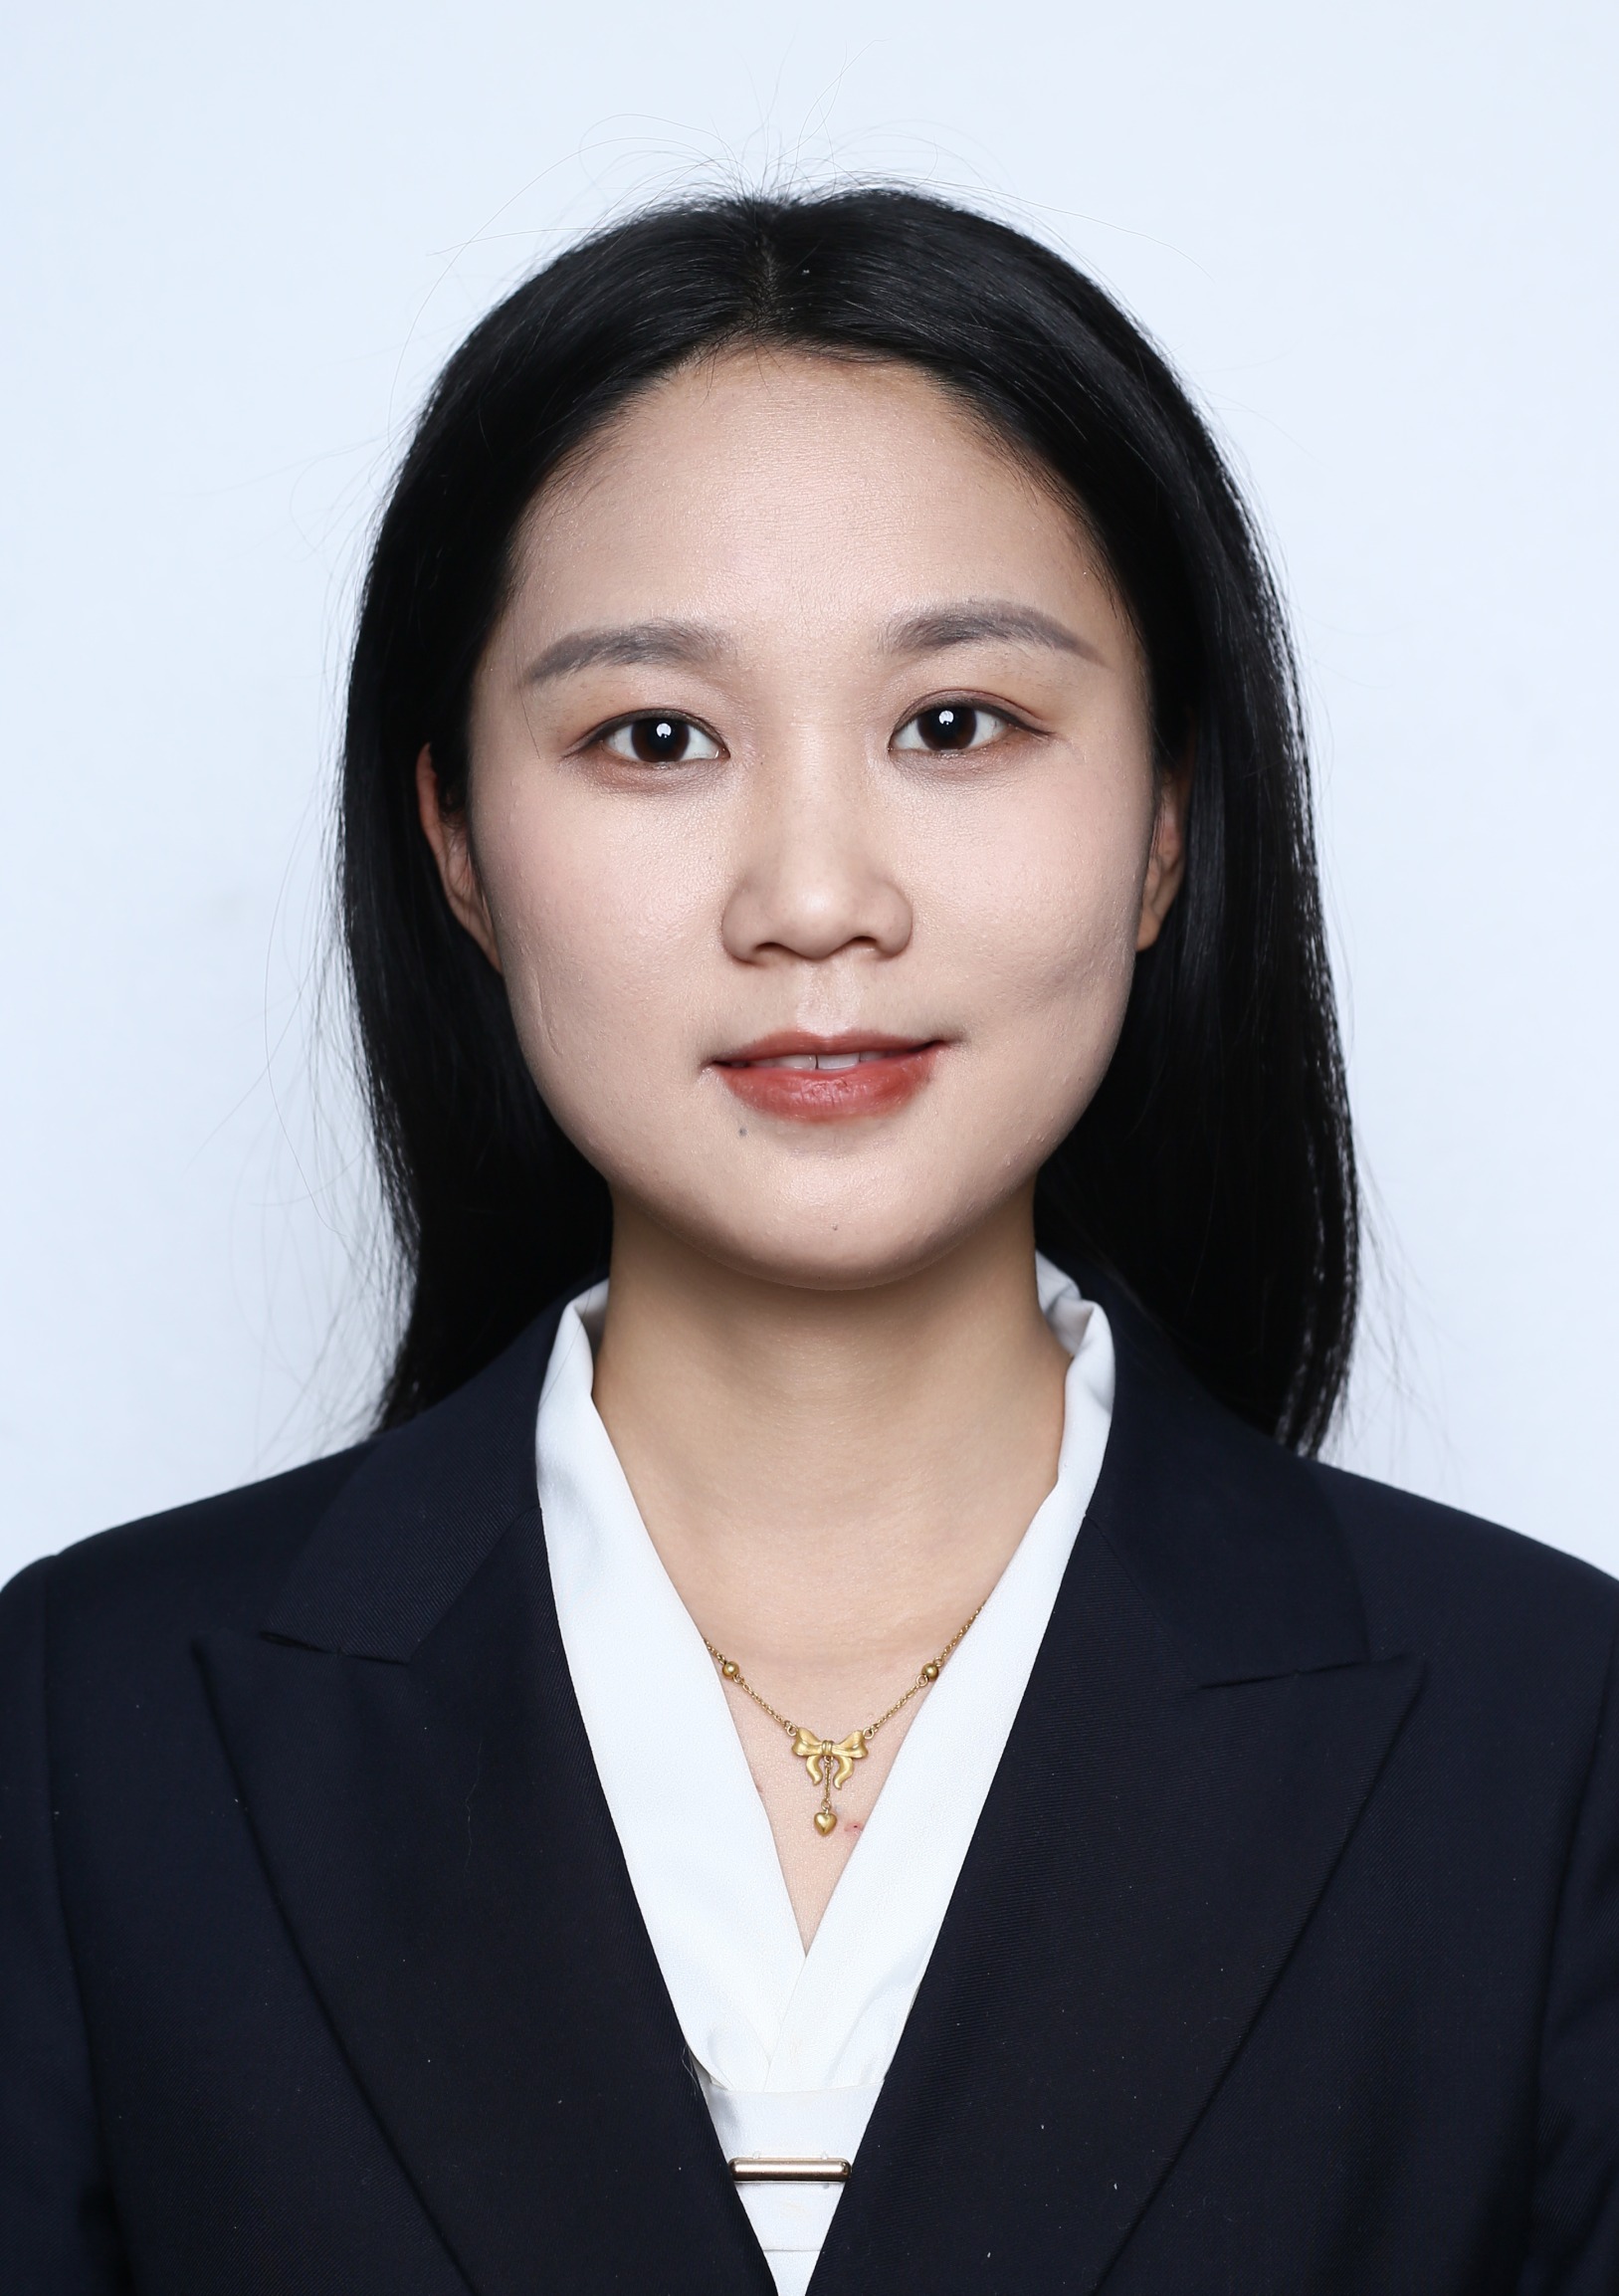
姓名:罗苗红
职务/职称:讲师
研究领域:分布式估计、协同控制、多智能体系统
邮箱:miaohong_luo@163.com
简要经历
2025.07-至今 郑州大学 讲师
2021.09-2025.06 华中科技大学 博士
2017.09-2020.06 郑州大学 硕士
主要项目
1. 国家自然科学基金青年科学基金项目,研究期限:2027.01- 2029.12,主持。
2. 中国博士后科学基金78批面上基金,研究期限:2025.12- 2027.08,主持。
3. 河南省科技攻关项目,研究期限:2026.01- 2027.11,主持。
其他
IEEE Transactions on Automatic Control,IEEE Transactions on Systems, Man, and Cybernetics: Systems,Journal of the Franklin Institute等期刊审稿人
论文
[1] Miaohong Luo, Housheng Su, Zhigang Zeng. Completely distributed joint state-unknown input estimation via interval observer. IEEE Transactions on Automatic Control, 2026, 71(8): 4986-5000 . (Regular paper)
[2] Miaohong Luo, Housheng Su, Zhigang Zeng. Resilient interval observer-based coordination control for multi-agent systems under stealthy attacks. Automatica, 2024, 167: 111781.
[3] Miaohong Luo, Housheng Su, Weixing Zheng. Interval observer-based coordination control for discrete-time multi-agent systems. IEEE Transactions on Systems, Man, and Cybernetics: Systems,2025,55(6): 4102-4114.
[4] Miaohong Luo , Qing An, Yin Chen, Housheng Su. Distributed unknown input estimation for LTI systems: An interval observer approach. Journal of the Franklin Institute, 2026, DOI: 10.1016/j.jfranklin.2026.108565.
[5] Miaohong Luo, Qin An, Housheng Su, Yin Chen. Unknown input observer-based consensus control of uncertain multi-agent systems under intermittent communication. Journal of the Franklin Institute, 2024, 361(18): 107351.
[6] Housheng Su, Miaohong Luo, Zhigang Zeng. Reduced-order interval observer-based coordination control for discrete-time multi-agent systems. Automatica, 2025, 174: 112131.
[7] Miaohong Luo, Xihui Wu, Xiaowu Mu, Zhe Yang. Nonfragile stabilization for semi-Markovian switching systems with actuator saturation via improved dynamic event-triggered scheme. International Journal of Robust and Nonlinear Control, 2021, 31(4): 1084-1102.
[8] Miaohong Luo, Xiaowu Mu, Xihui Wu, Zenghui Hu. Event-triggered non-fragile finite-time H∞ control for semi-Markovian jump systems with actuator saturation. Journal of the Franklin Institute, 2020, 357(15): 10626-10647.